Xue Bin (Jason) Peng
I'm an Assistant Professor at Simon Fraser University (SFU) and a Research Scientist at NVIDIA. I hold a Canada CIFAR AI Chair through Amii. I will be moving to the University of British Columbia (UBC) in 2027.
I received a Ph.D. from UC Berkeley, advised by Professor Sergey Levine and Professor Pieter Abbeel. Prior to that, I received an M.Sc from the University of British Columbia, advised by Professor Michiel van de Panne. My work lies in the intersection between computer graphics and machine learning, with a focus on reinforcement learning for motion control of simulated characters. I have previously worked for Google, OpenAI, Adobe Research, Disney Research, Microsoft (343 Industries), and Capcom.
Codebase
Publications
2026
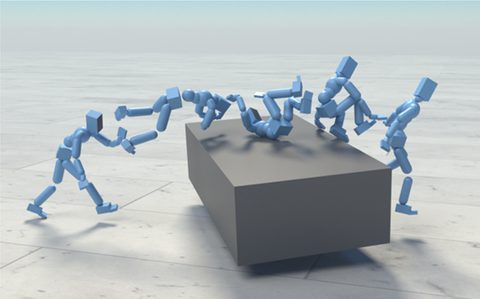
HIL: Hybrid Imitation Learning for Dynamic Athletic Control
ACM Transactions on Graphics (TOG 2026)
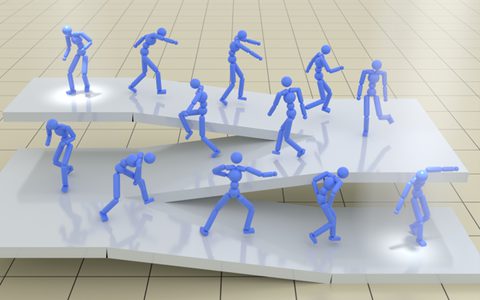
SMP: Reusable Score-Matching Motion Priors for Physics-Based Character Control
ACM Transactions on Graphics (Proc. SIGGRAPH 2026)
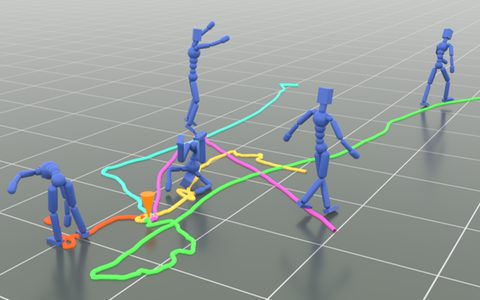
MotionBricks: Scalable Real-Time Motions with Modular Latent Generative Model and Smart Primitives
ACM Transactions on Graphics (Proc. SIGGRAPH 2026)
Robo-Saber: Generating and Simulating Virtual Reality Players
Conference of the European Association for Computer Graphics (Eurographics 2026)
2025
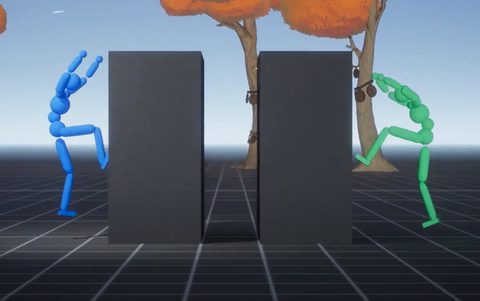
Physics-Based Motion Imitation with Adversarial Differential Discriminators
ACM SIGGRAPH Asia 2025
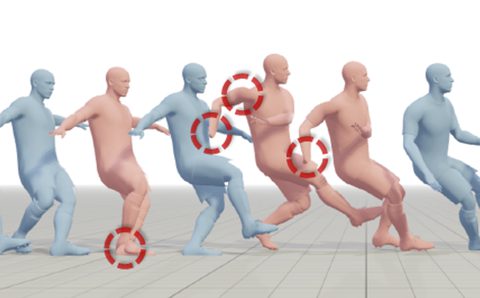
StableMotion: Training Motion Cleanup Models with Unpaired Corrupted Data
ACM SIGGRAPH Asia 2025
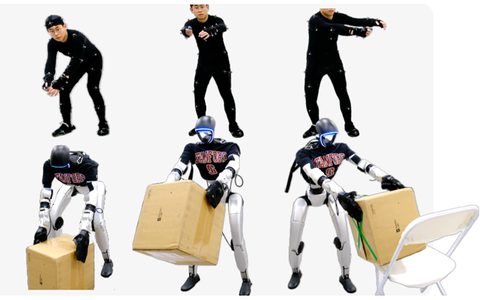
TWIST: Teleoperated Whole-Body Imitation System
Conference on Robot Learning (CoRL 2025)
Learning Smooth Humanoid Locomotion through Lipschitz-Constrained Policies
IEEE International Conference on Intelligent Robots and Systems (IROS 2025)
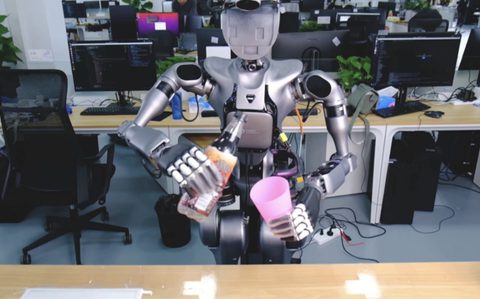
Generalizable Humanoid Manipulation with 3D Diffusion Policies
IEEE International Conference on Intelligent Robots and Systems (IROS 2025)
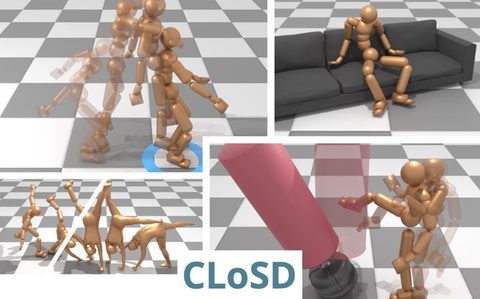
CLoSD: Closing the Loop Between Simulation and Diffusion for Multi-Task Character Control
International Conference on Learning Representations (ICLR 2025)
Spotlight
2024
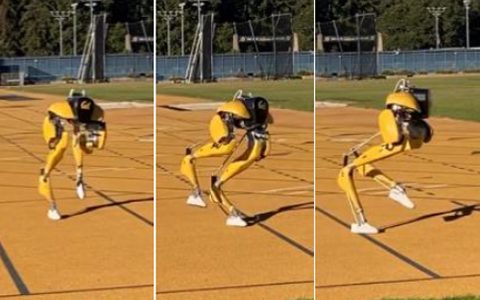
Reinforcement Learning for Versatile, Dynamic, and Robust Bipedal Locomotion Control
The International Journal of Robotics Research (IJRR 2024)
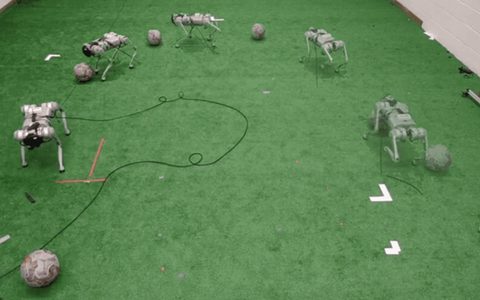
HiLMa-Res: A General Hierarchical Framework via Residual RL for Combining Quadrupedal Locomotion and Manipulation
IEEE International Conference on Intelligent Robots and Systems (IROS 2024)
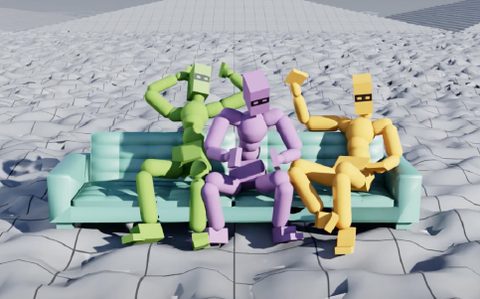
MaskedMimic: Unified Physics-Based Character Control Through Masked Motion Inpainting
ACM Transactions on Graphics (Proc. SIGGRAPH Asia 2024)
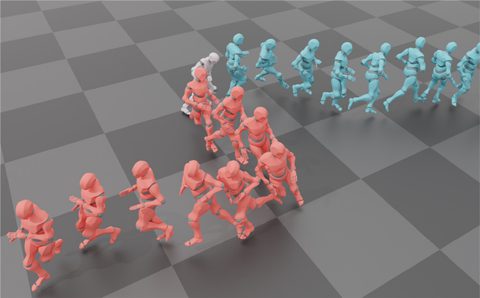
Interactive Character Control with Auto-Regressive Motion Diffusion Models
ACM Transactions on Graphics (Proc. SIGGRAPH 2024)
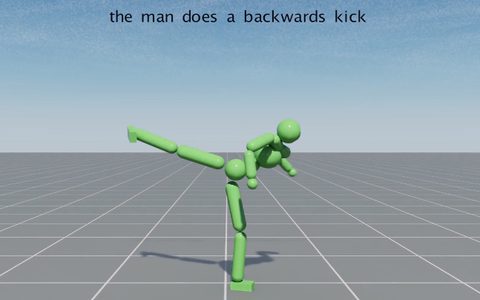
Generating Human Interaction Motions in Scenes with Text Control
European Conference on Computer Vision (ECCV 2024)
Multi-Track Timeline Control for Text-Driven 3D Human Motion Generation
CVPR Workshop on Human Motion Generation (CVPR Workshop 2024)
Trajeglish: Traffic Modeling as Next-Token Prediction
International Conference on Learning Representations (ICLR 2024)
2023
Learning Physically Simulated Tennis Skills from Broadcast Videos
ACM Transactions on Graphics (Proc. SIGGRAPH 2023)
Best Paper Honourable Mention
Video Prediction Models as Rewards for Reinforcement Learning
Neural Information Processing Systems (NeurIPS 2023)
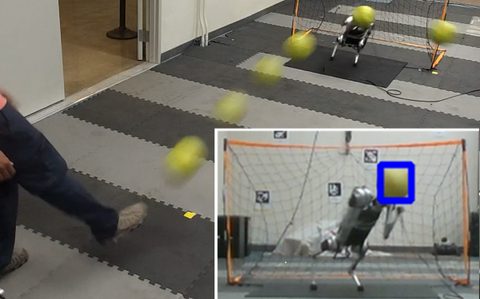
Creating a Dynamic Quadrupedal Robotic Goalkeeper with Reinforcement Learning
IEEE International Conference on Intelligent Robots and Systems (IROS 2023)
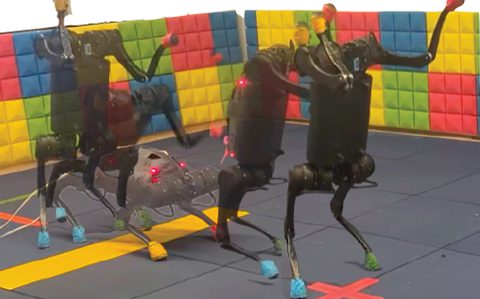
Learning and Adapting Agile Locomotion Skills by Transferring Experience
Robotics: Science and Systems (RSS 2023)
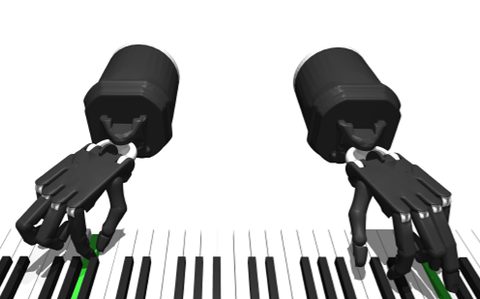
RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning
Conference on Robot Learning (CoRL 2023)
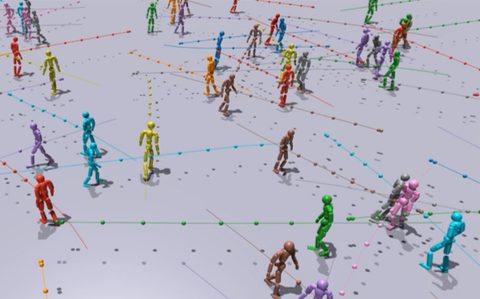
Trace and Pace: Controllable Pedestrian Animation via Guided Trajectory Diffusion
Conference on Computer Vision and Pattern Recognition (CVPR 2023)
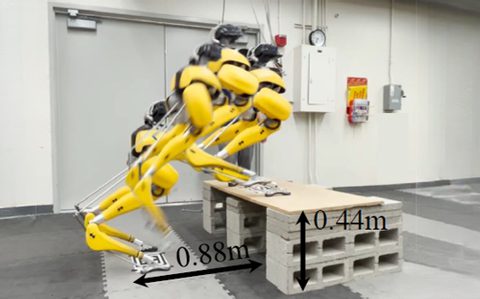
Robust and Versatile Bipedal Jumping Control through Reinforcement Learning
Robotics: Science and Systems (RSS 2023)
2022
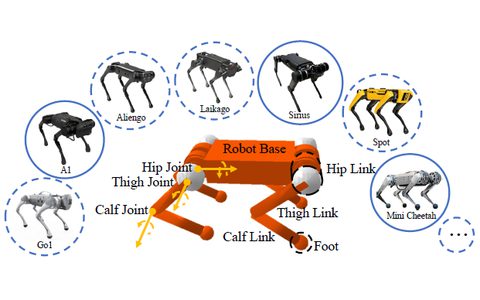
GenLoco: Generalized Locomotion Controllers for Quadrupedal Robots
Conference on Robot Learning (CoRL 2022)
Unsupervised Reinforcement Learning with Contrastive Intrinsic Control
Neural Information Processing Systems (NeurIPS 2022)
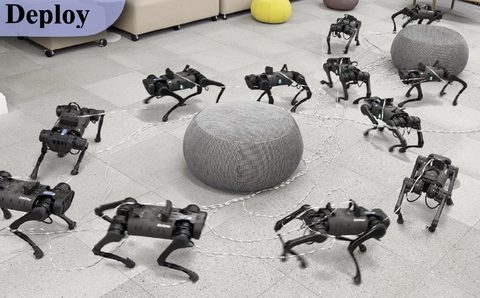
Adversarial Motion Priors Make Good Substitutes for Complex Reward Functions
IEEE International Conference on Intelligent Robots and Systems (IROS 2022)
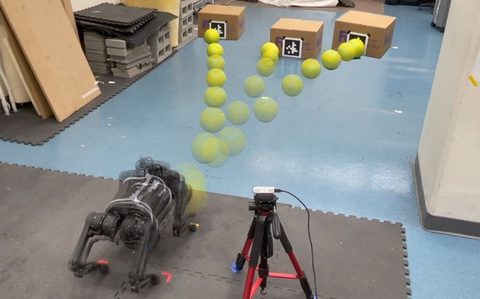
Hierarchical Reinforcement Learning for Precise Soccer Shooting Skills using a Quadrupedal Robot
IEEE International Conference on Intelligent Robots and Systems (IROS 2022)
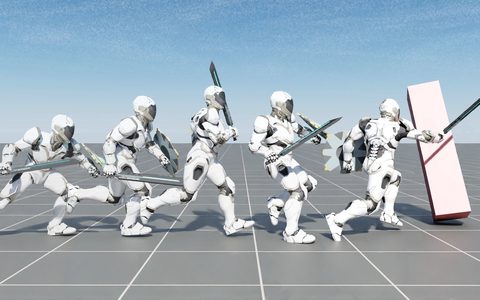
ASE: Large-Scale Reusable Adversarial Skill Embeddings for Physically Simulated Characters
ACM Transactions on Graphics (Proc. SIGGRAPH 2022)
Legged Robots that Keep on Learning: Fine-Tuning Locomotion Policies in the Real World
IEEE International Conference on Robotics and Automation (ICRA 2022)
2021
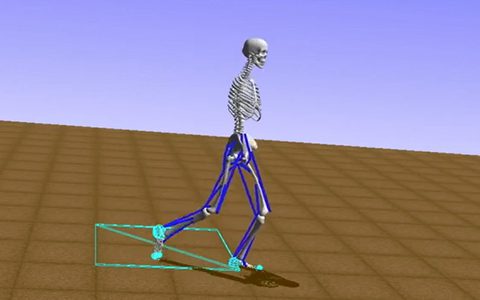
Deep Reinforcement Learning for Modeling Human Locomotion Control in Neuromechanical Simulation
Journal of NeuroEngineering and Rehabilitation 2021
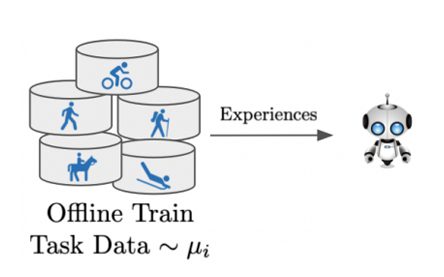
Offline Meta-Reinforcement Learning with Advantage Weighting
International Conference on Machine Learning (ICML 2021)
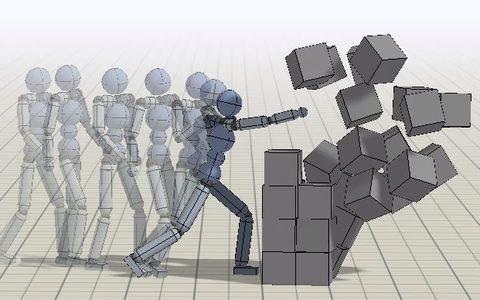
AMP: Adversarial Motion Priors for Stylized Physics-Based Character Control
ACM Transactions on Graphics (Proc. SIGGRAPH 2021)
Reinforcement Learning for Robust Parameterized Locomotion Control of Bipedal Robots
IEEE International Conference on Robotics and Automation (ICRA 2021)
2020
Learning Agile Robotic Locomotion Skills by Imitating Animals
Robotics: Science and Systems (RSS 2020)
Best Paper Award
Reinforcement Learning with Competitive Ensembles of Information-Constrained Primitives
International Conference on Learning Representations (ICLR 2020)
2019
On Learning Symmetric Locomotion
ACM SIGGRAPH Conference on Motion, Interaction, and Games (MIG 2019)
MCP: Learning Composable Hierarchical Control with Multiplicative Compositional Policies
Neural Information Processing Systems (NeurIPS 2019)
Variational Discriminator Bottleneck: Improving Imitation Learning, Inverse RL, and GANs by Constraining Information Flow
International Conference on Learning Representations (ICLR 2019)
2018
SFV: Reinforcement Learning of Physical Skills from Videos
ACM Transactions on Graphics (Proc. SIGGRAPH Asia 2018)
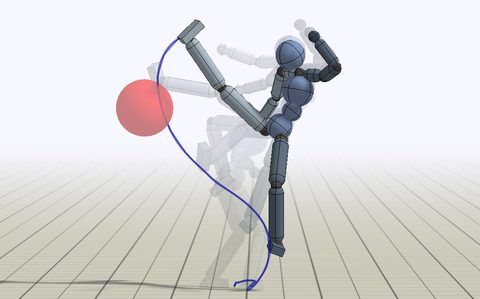
DeepMimic: Example-Guided Deep Reinforcement Learning of Physics-Based Character Skills
ACM Transactions on Graphics (Proc. SIGGRAPH 2018)
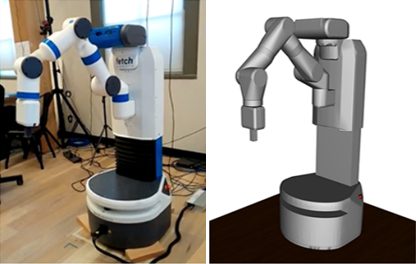
Sim-to-Real Transfer of Robotic Control with Dynamics Randomization
IEEE International Conference on Robotics and Automation (ICRA 2018)
2017
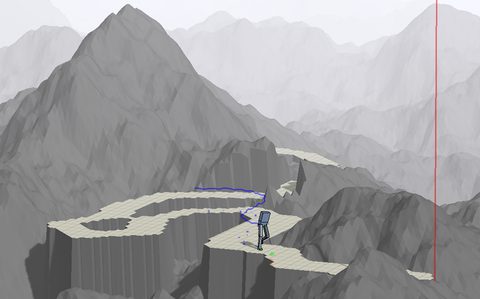
DeepLoco: Dynamic Locomotion Skills Using Hierarchical Deep Reinforcement Learning
ACM Transactions on Graphics (Proc. SIGGRAPH 2017)
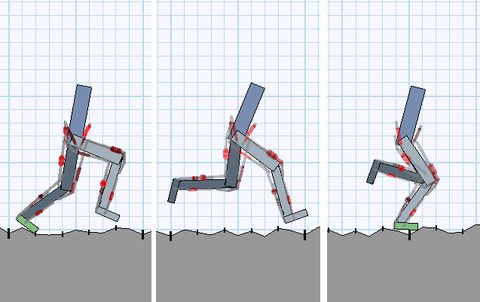
Learning Locomotion Skills Using DeepRL: Does the Choice of Action Space Matter?
ACM SIGGRAPH / Eurographics Symposium on Computer Animation 2017
Best Student Paper Award
2016
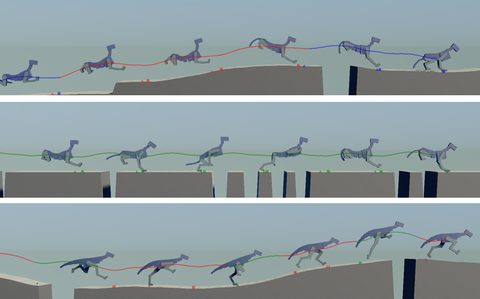
Terrain-Adaptive Locomotion Skills Using Deep Reinforcement Learning
ACM Transactions on Graphics (Proc. SIGGRAPH 2016)
2015
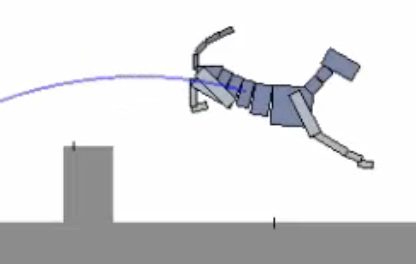
Dynamic Terrain Traversal Skills Using Reinforcement Learning
ACM Transactions on Graphics (Proc. SIGGRAPH 2015)
Thesis
Acquiring Motor Skills Through Motion Imitation and Reinforcement Learning
University of California, Berkeley 2021
Developing Locomotion Skills with Deep Reinforcement Learning
University of British Columbia 2017