TWIST: Teleoperated Whole-Body Imitation System
- 1Stanford University
- 2Simon Fraser University
Abstract
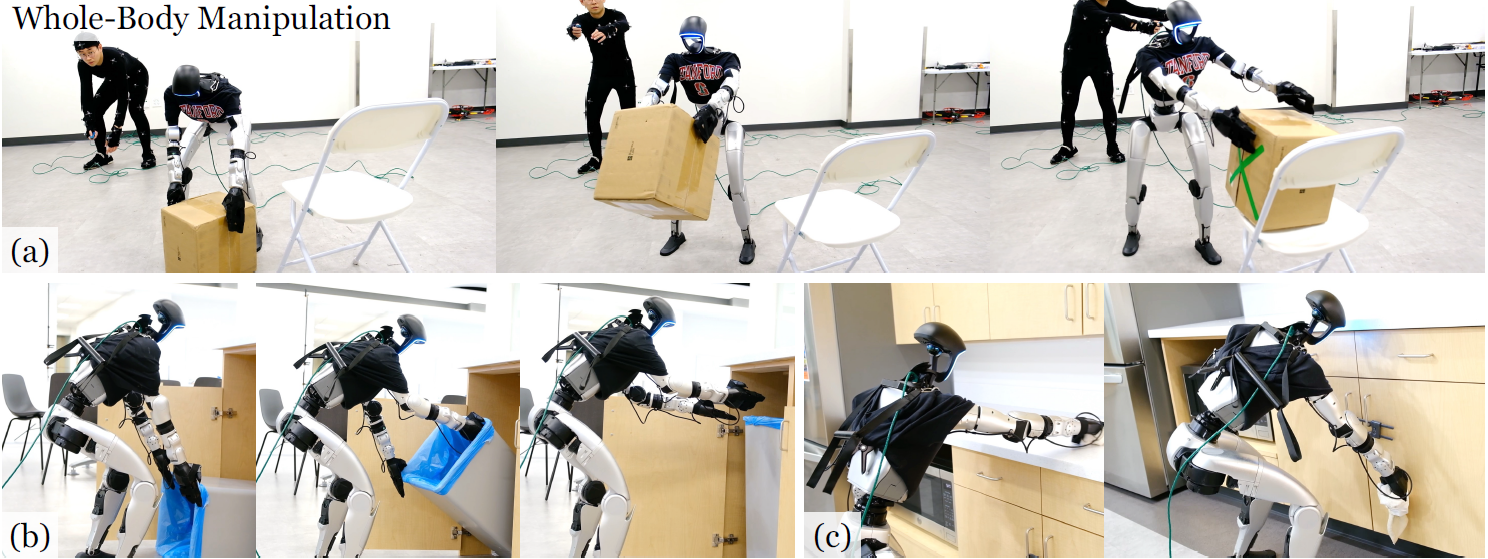
Teleoperating humanoid robots in a whole-body manner marks a fundamental step toward developing general-purpose robotic intelligence, with human motion providing an ideal interface for controlling all degrees of freedom. Yet, most current humanoid teleoperation systems fall short of enabling coordinated whole-body behavior, typically limiting themselves to isolated locomotion or manipulation tasks. We present the Teleoperated Whole-Body Imitation System (TWIST), a system for humanoid teleoperation through whole-body motion imitation. We first generate reference motion clips by retargeting human motion capture data to the humanoid robot. We then develop a robust, adaptive, and responsive whole-body controller using a combination of reinforcement learning and behavior cloning (RL+BC). Through systematic analysis, we demonstrate how incorporating privileged future motion frames and real-world motion capture (MoCap) data improves tracking accuracy. TWIST enables real-world humanoid robots to achieve unprecedented, versatile, and coordinated whole-body motor skills—spanning whole-body manipulation, legged manipulation, locomotion, and expressive movement—using a single unified neural network controller.
Video
BibTeX
@InProceedings{
	ze2025twist,
	title = {TWIST: Teleoperated Whole-Body Imitation System},
	author = {Ze, Yanjie and Chen, Zixuan and Araujo, Joao Pedro and Cao, Zi-ang and Peng, Xue Bin and Wu, Jiajun and Liu, Karen},
	booktitle = {Proceedings of The 9th Conference on Robot Learning},
	pages = {2143--2154},
	year = {2025},
	editor = {Lim, Joseph and Song, Shuran and Park, Hae-Won},
	volume = {305},
	series = {Proceedings of Machine Learning Research},
	month = {27--30 Sep},
	publisher = {PMLR},
	pdf = {https://raw.githubusercontent.com/mlresearch/v305/main/assets/ze25a/ze25a.pdf},
	url = {https://proceedings.mlr.press/v305/ze25a.html},
}