On Learning Symmetric Locomotion
- 1University of British Columbia
- 2University of California, Berkeley
Abstract
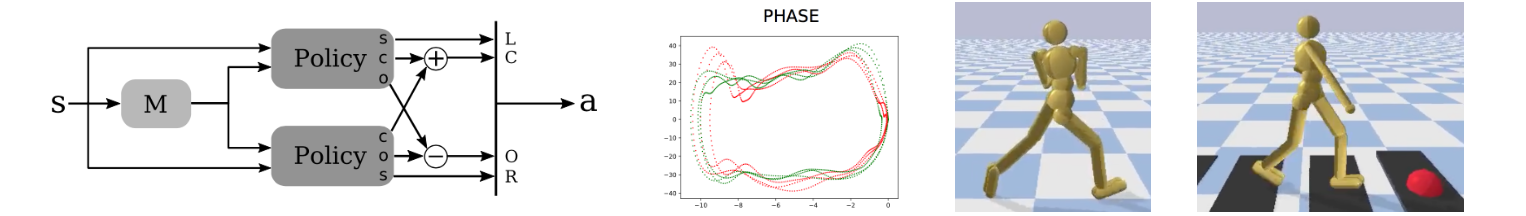
Human and animal gaits are often symmetric in nature, which points to the use of motion symmetry as a potentially useful source of structure that can be exploited for learning. By encouraging symmetric motion, the learning may be faster, converge to more efficient solutions, and be more aesthetically pleasing. We describe, compare, and evaluate four practical methods for encouraging motion symmetry. These are implemented via particular choices of structure for the policy network, data duplication, or via the loss function. We experimentally evaluate the methods in terms of learning performance and achieved symmetry, and provide summary guidelines for the choice of symmetry method. We further describe some practical and conceptual issues that arise. Because similar implementation choices exist for other types of inductive biases, the insights gained may also be relevant to other learning problems with applicable symmetry abstractions.
Video
BibTeX
@inproceedings{2019-MIG-symmetry,
author = {Abdolhosseini, Farzad and Ling, Hung Yu and Xie, Zhaoming and Peng, Xue Bin and van de Panne, Michiel},
title = {On Learning Symmetric Locomotion},
year = {2019},
isbn = {9781450369947},
publisher = {Association for Computing Machinery},
address = {New York, NY, USA},
url = {https://doi.org/10.1145/3359566.3360070},
doi = {10.1145/3359566.3360070},
booktitle = {Motion, Interaction and Games},
articleno = {19},
numpages = {10},
keywords = {locomotion, reinforcement learning, symmetry},
location = {Newcastle upon Tyne, United Kingdom},
series = {MIG '19}
}