RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning
- 1University of California, Berkeley
- 2Google DeepMind
- 3Stanford University
- 4Simon Fraser University
Abstract
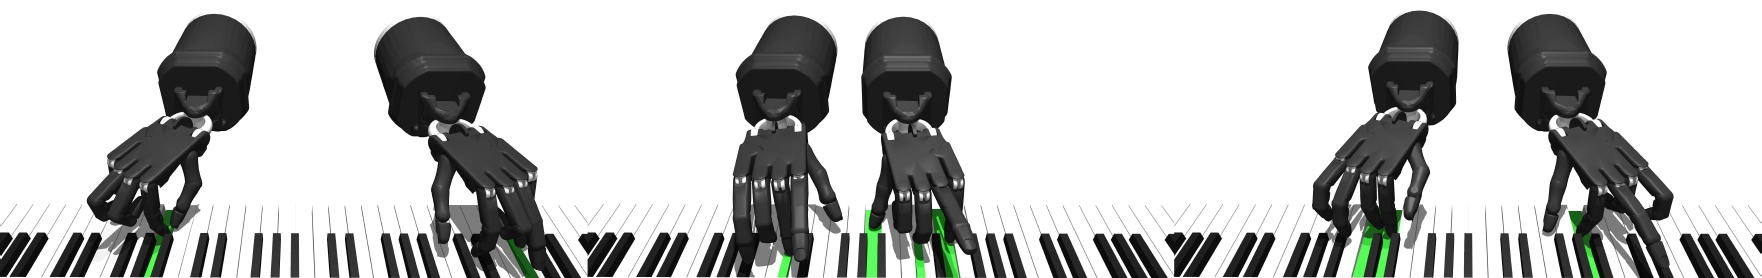
Replicating human-like dexterity in robot hands represents one of the largest open problems in robotics. Reinforcement learning is a promising approach that has achieved impressive progress in the last few years; however, the class of problems it has typically addressed corresponds to a rather narrow definition of dexterity as compared to human capabilities. To address this gap, we investigate piano-playing, a skill that challenges even the human limits of dexterity, as a means to test high-dimensional control, and which requires high spatial and temporal precision, and complex finger coordination and planning. We introduce ROBOPIANIST, a system that enables simulated anthropomorphic hands to learn an extensive repertoire of 150 piano pieces where traditional model-based optimization struggles. We additionally introduce an open-sourced environment, benchmark of tasks, interpretable evaluation metrics, and open challenges for future study.
Video
BibTeX
@InProceedings{
	RoboPianistZakka2023,
	title={RoboPianist: Dexterous Piano Playing with Deep Reinforcement Learning},
	author={Zakka, Kevin and Wu, Philipp and Smith, Laura and Gileadi, Nimrod and Howell, Taylor and Peng, Xue Bin and Singh, Sumeet and Tassa, Yuval and Florence, Pete and Zeng, Andy and Abbeel, Pieter},
	booktitle={Proceedings of The 7th Conference on Robot Learning},
	pages={2975--2994},
	year={2023},
	editor={Tan, Jie and Toussaint, Marc and Darvish, Kourosh},
	volume={229},
	series={Proceedings of Machine Learning Research},
	month={06--09 Nov},
	publisher={PMLR},
	pdf={https://proceedings.mlr.press/v229/zakka23a/zakka23a.pdf},
	url={https://proceedings.mlr.press/v229/zakka23a.html}
}