MaskedManipulator: Versatile Whole-Body Manipulation
- 1NVIDIA
- 2Simon Fraser University
Abstract
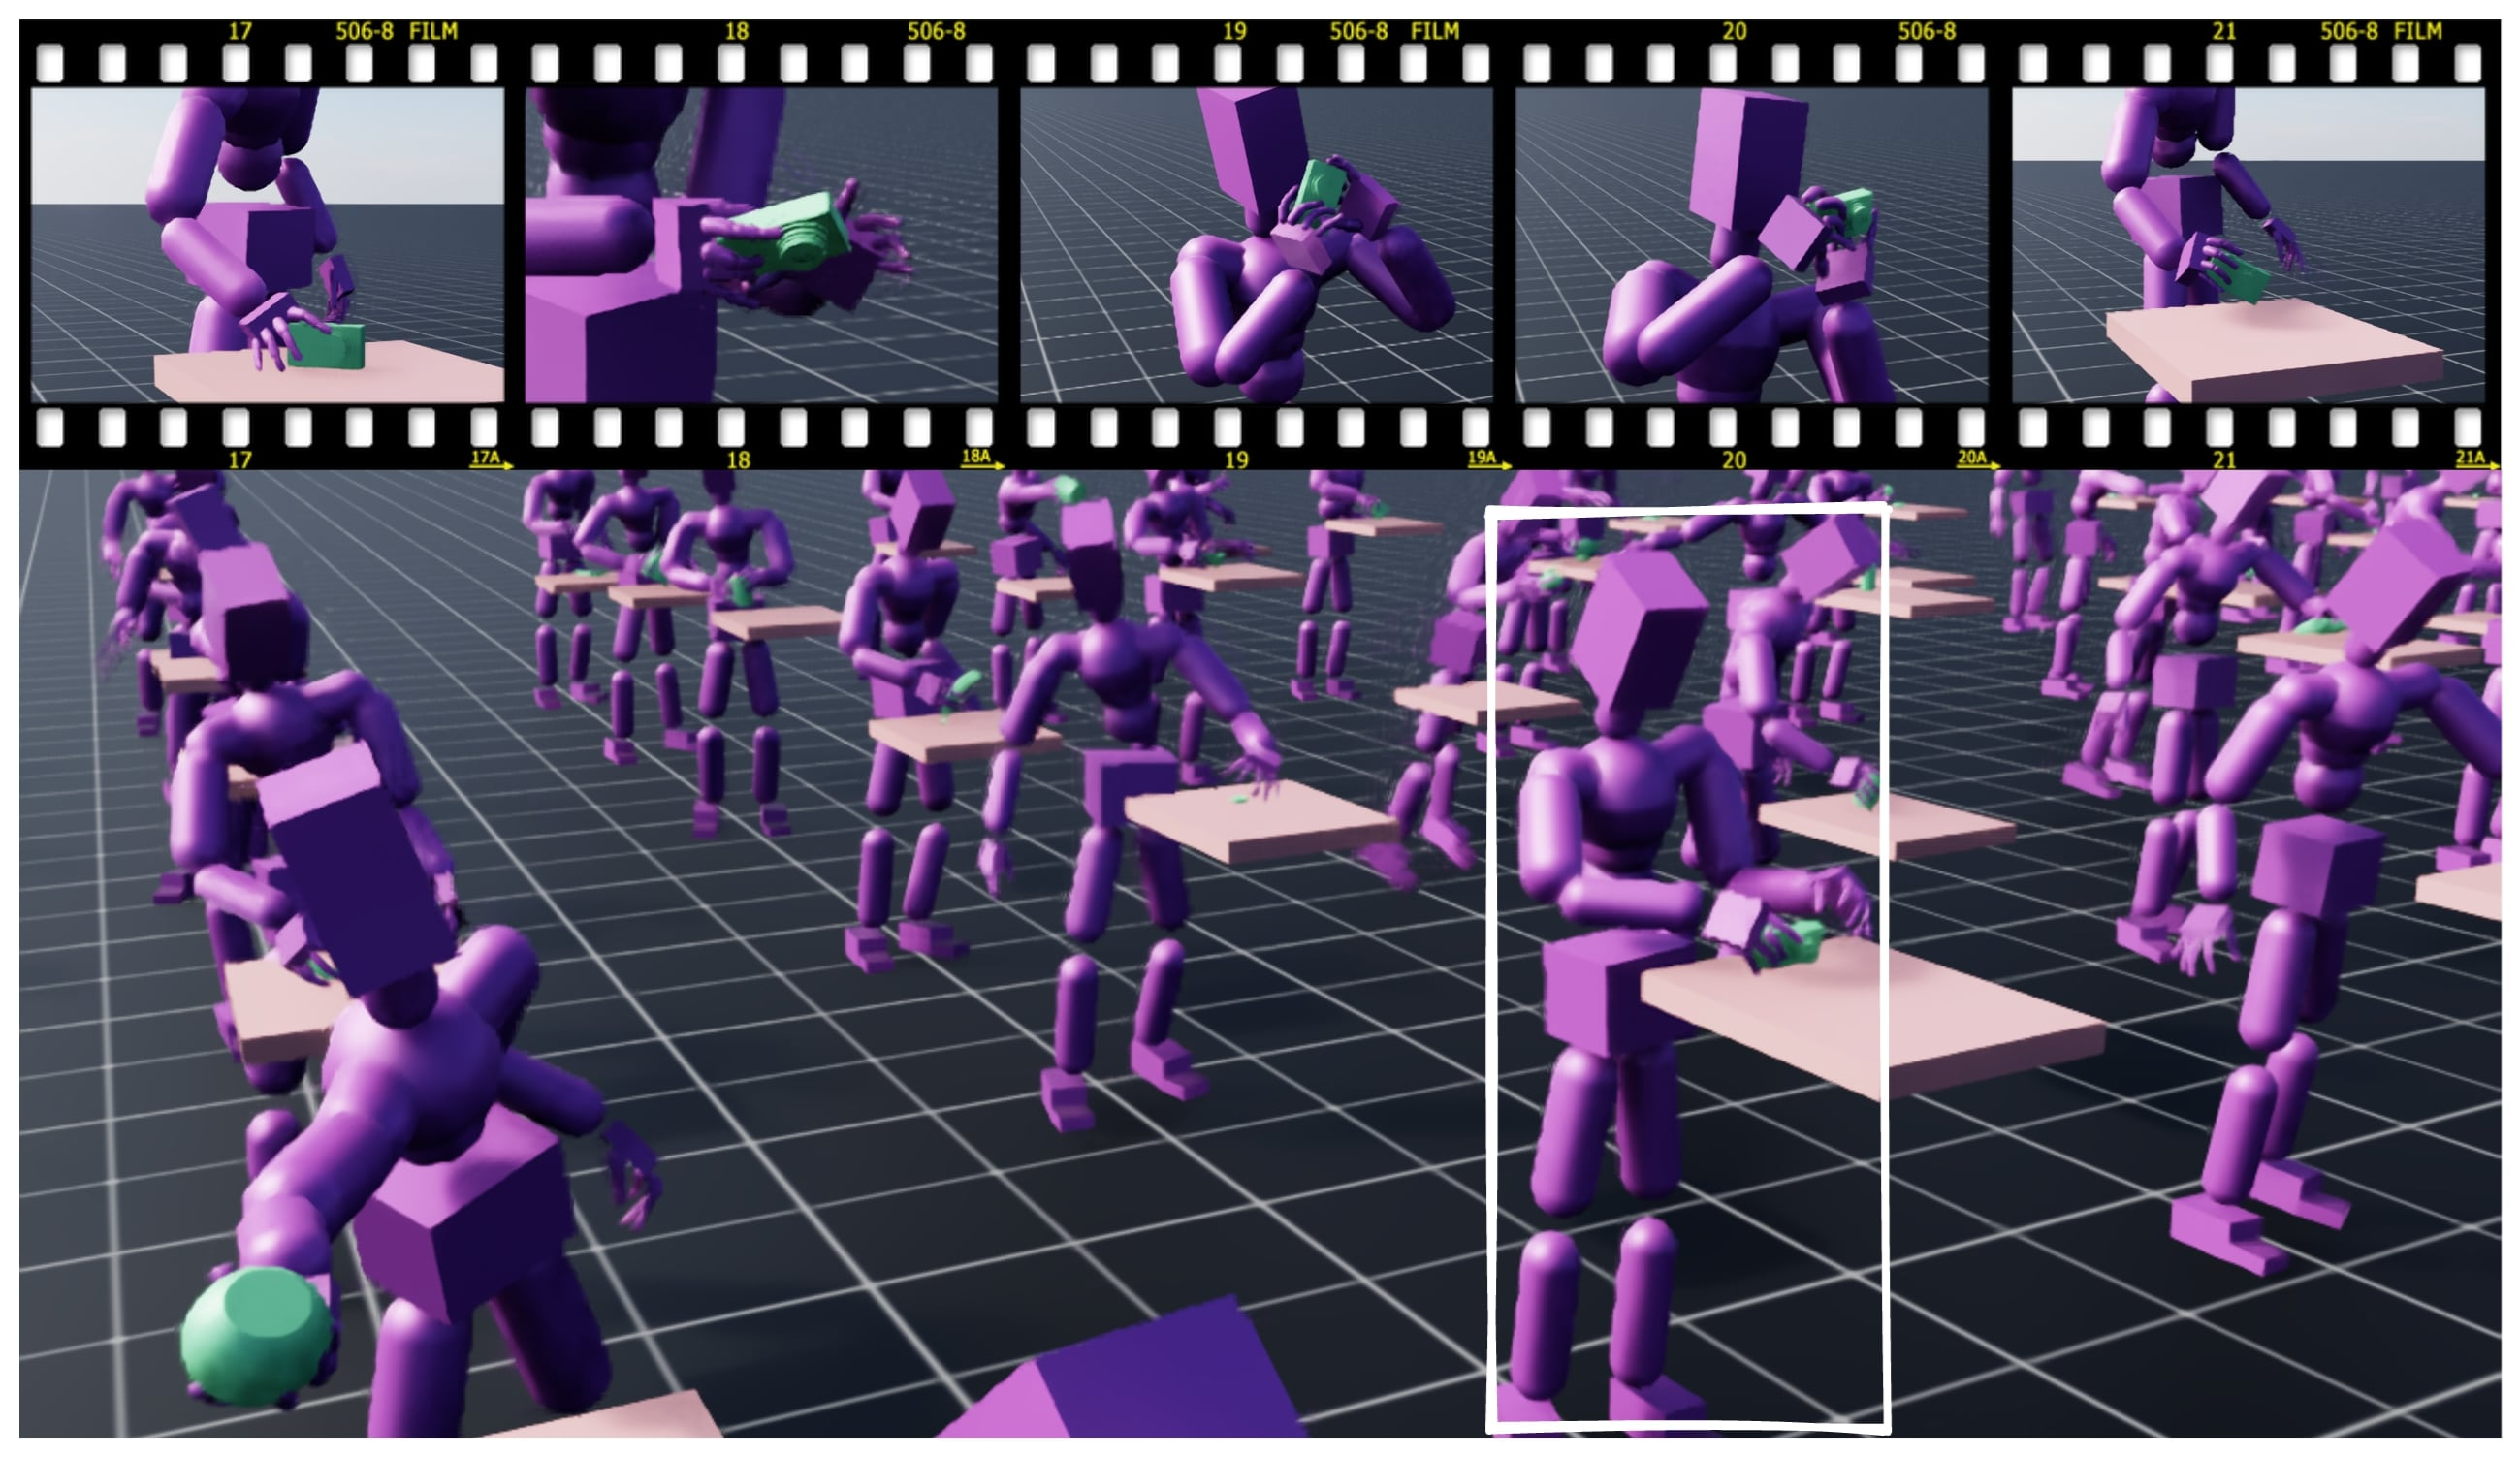
We tackle the challenges of synthesizing versatile, physically simulated human motions for full-body object manipulation. Unlike prior methods that are focused on detailed motion tracking, trajectory following, or teleoperation, our framework enables users to specify versatile high-level objectives such as target object poses or body poses. To achieve this, we introduce MaskedManipulator, a generative control policy distilled from a tracking controller trained on large-scale human motion capture data. This two-stage learning process allows the system to perform complex interaction behaviors, while providing intuitive user control over both character and object motions. MaskedManipulator produces goal-directed manipulation behaviors that expand the scope of interactive animation systems beyond task-specific solutions.
Video
BibTeX
@inproceedings{tessler2025maskedmanipulator,
    author = {Tessler, Chen and Jiang, Yifeng and Coumans, Erwin and Luo, Zhengyi and Chechik, Gal and Peng, Xue Bin},
    title = {MaskedManipulator: Versatile Whole-Body Manipulation},
    year = {2025},
    booktitle={ACM SIGGRAPH Asia 2025 Conference Proceedings}
}