Humanoid Locomotion and Manipulation: Current Progress and Challenges in Control, Planning, and Learning
- 1Georgia Institute of Technology
- 2The University of Southern California
- 3Technische Universität München
- 4Google DeepMind
- 5The Robotics AI Institute
- 6The Institute for Human and Machine Cognition
- 7Duke University
- 8Kuwait University
- 9Stanford University
- 10CNRS-University of Montpellier LIRMM
- 11CNRS-AIST Joint Robotics Laboratory
- 12Simon Fraser University
- 13The University of Texas at Austin
- 14NVIDIA
- 15Carnegie Mellon University
- 16Harbin Institute of Technology
Abstract
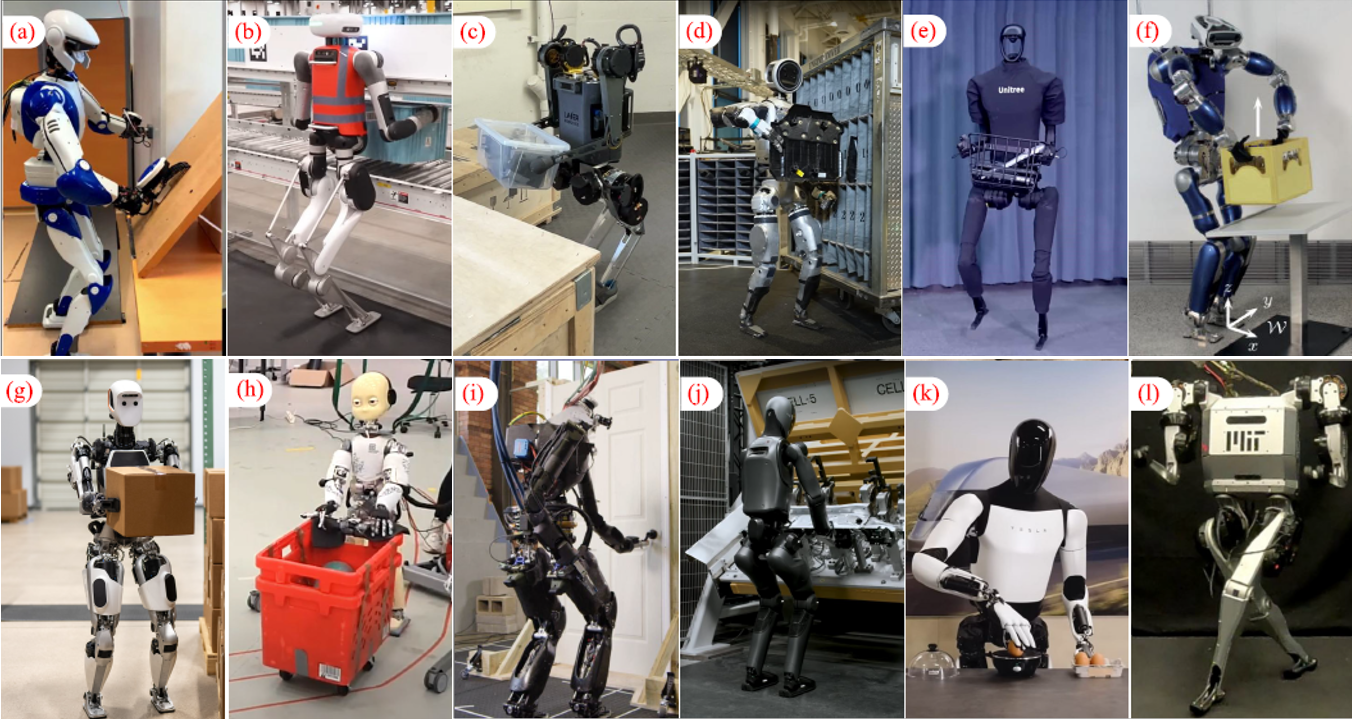
Humanoid robots hold great potential to perform various human-level skills, involving unified locomotion and manipulation in real-world settings. Driven by advances in machine learning and the strength of existing model-based approaches, these capabilities have progressed rapidly, but often separately. This survey offers a comprehensive overview of the state-ofthe-art in humanoid locomotion and manipulation (HLM), with a focus on control, planning, and learning methods. We first review the model-based methods that have been the backbone of humanoid robotics for the past three decades. We discuss contact planning, motion planning, and whole-body control, highlighting the trade-offs between model fidelity and computational efficiency. Then the focus is shifted to examine emerging learningbased methods, with an emphasis on reinforcement and imitation learning that enhance the robustness and versatility of locomanipulation skills. Furthermore, we assess the potential of integrating foundation models with humanoid embodiments to enable the development of generalist humanoid agents. This survey also highlights the emerging role of tactile sensing, particularly whole-body tactile feedback, as a crucial modality for handling contact-rich interactions. Finally, we compare the strengths and limitations of model-based and learning-based paradigms from multiple perspectives, such as robustness, computational efficiency, versatility, and generalizability and suggest potential solutions to existing challenges.
BibTeX
@article{
  Gu2026HumanoidReview,
  author = {Gu, Zhaoyuan and Li, Junheng and Shen, Wenlan and Yu, Wenhao and Xie, Zhaoming and McCrory, Stephen and Cheng, Xianyi and Shamsah, Abdulaziz and Griffin, Robert and Liu, C. Karen and Kheddar, Abderrahmane and Peng, Xue Bin and Zhu, Yuke and Shi, Guanya and Nguyen, Quan and Cheng, Gordon and Gao, Huijun and Zhao, Ye},
  journal = {IEEE/ASME Transactions on Mechatronics},
  title = {Humanoid Locomotion and Manipulation: Current Progress and Challenges in Control, Planning, and Learning},
  year = {2026},
  volume = {31},
  number = {2},
  pages = {2300-2330},
  doi = {10.1109/TMECH.2025.3579247}
}