CLoSD: Closing the Loop Between Simulation and Diffusion for Multi-Task Character Control
- 1Tel-Aviv University
- 2University of British Columbia
- 3Carnegie Mellon University
- 4Simon Fraser University
- 5NVIDIA
Abstract
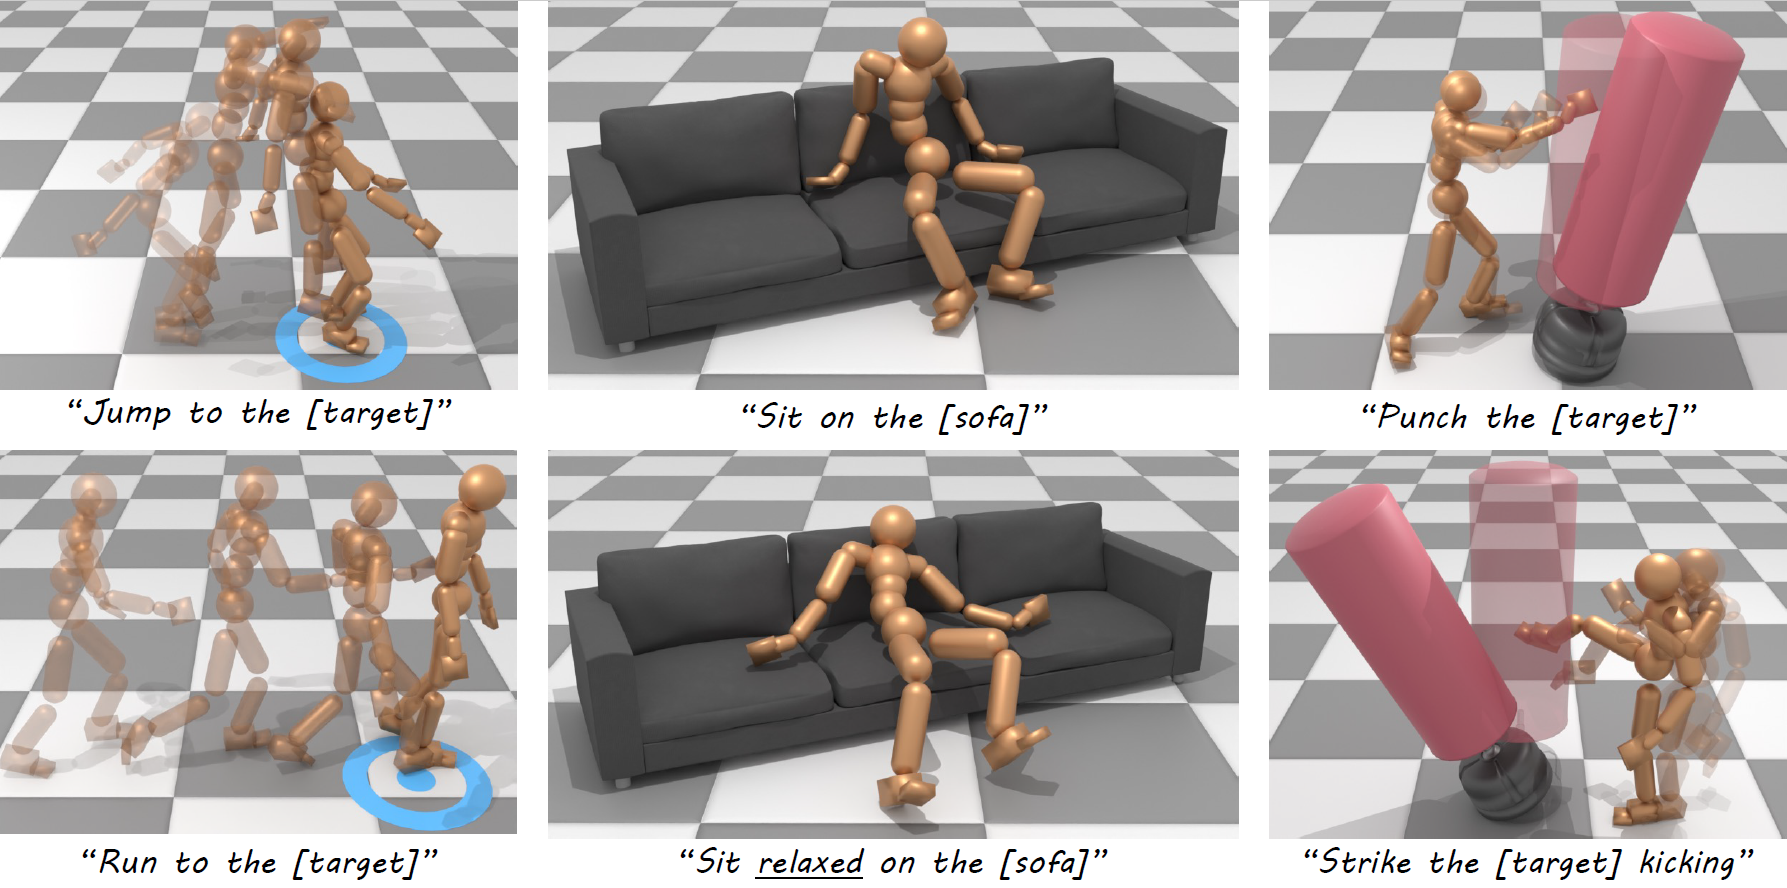
Motion diffusion models and Reinforcement Learning (RL) based control for physics-based simulations have complementary strengths for human motion generation. The former is capable of generating a wide variety of motions, adhering to intuitive control such as text, while the latter offers physically plausible motion and direct interaction with the environment. In this work, we present a method that combines their respective strengths. CLoSD is a text-driven RL physics-based controller, guided by diffusion generation for various tasks. Our key insight is that motion diffusion can serve as an on-the-fly universal planner for a robust RL controller. To this end, CLoSD maintains a closed-loop interaction between two modules — a Diffusion Planner (DiP), and a tracking controller. DiP is a fast-responding autoregressive diffusion model, controlled by textual prompts and target locations, and the controller is a simple and robust motion imitator that continuously receives motion plans from DiP and provides feedback from the environment. CLoSD is capable of seamlessly performing a sequence of different tasks, including navigation to a goal location, striking an object with a hand or foot as specified in a text prompt, sitting down, and getting up.
Video
BibTeX
@inproceedings{
    tevet2025closd,
    title={CLoSD: Closing the Loop between Simulation and Diffusion for multi-task character control},
    author={Guy Tevet and Sigal Raab and Setareh Cohan and Daniele Reda and Zhengyi Luo and Xue Bin Peng and Amit Haim Bermano and Michiel van de Panne},
    booktitle={The Thirteenth International Conference on Learning Representations},
    year={2025},
    url={https://openreview.net/forum?id=pZISppZSTv}
}