CALM: Conditional Adversarial Latent Models for Directable Virtual Characters
- 1NVIDIA
- 2Technion - Israel Institute of Technology
- 3Bar-Ilan University
- 4Simon Fraser University
Abstract
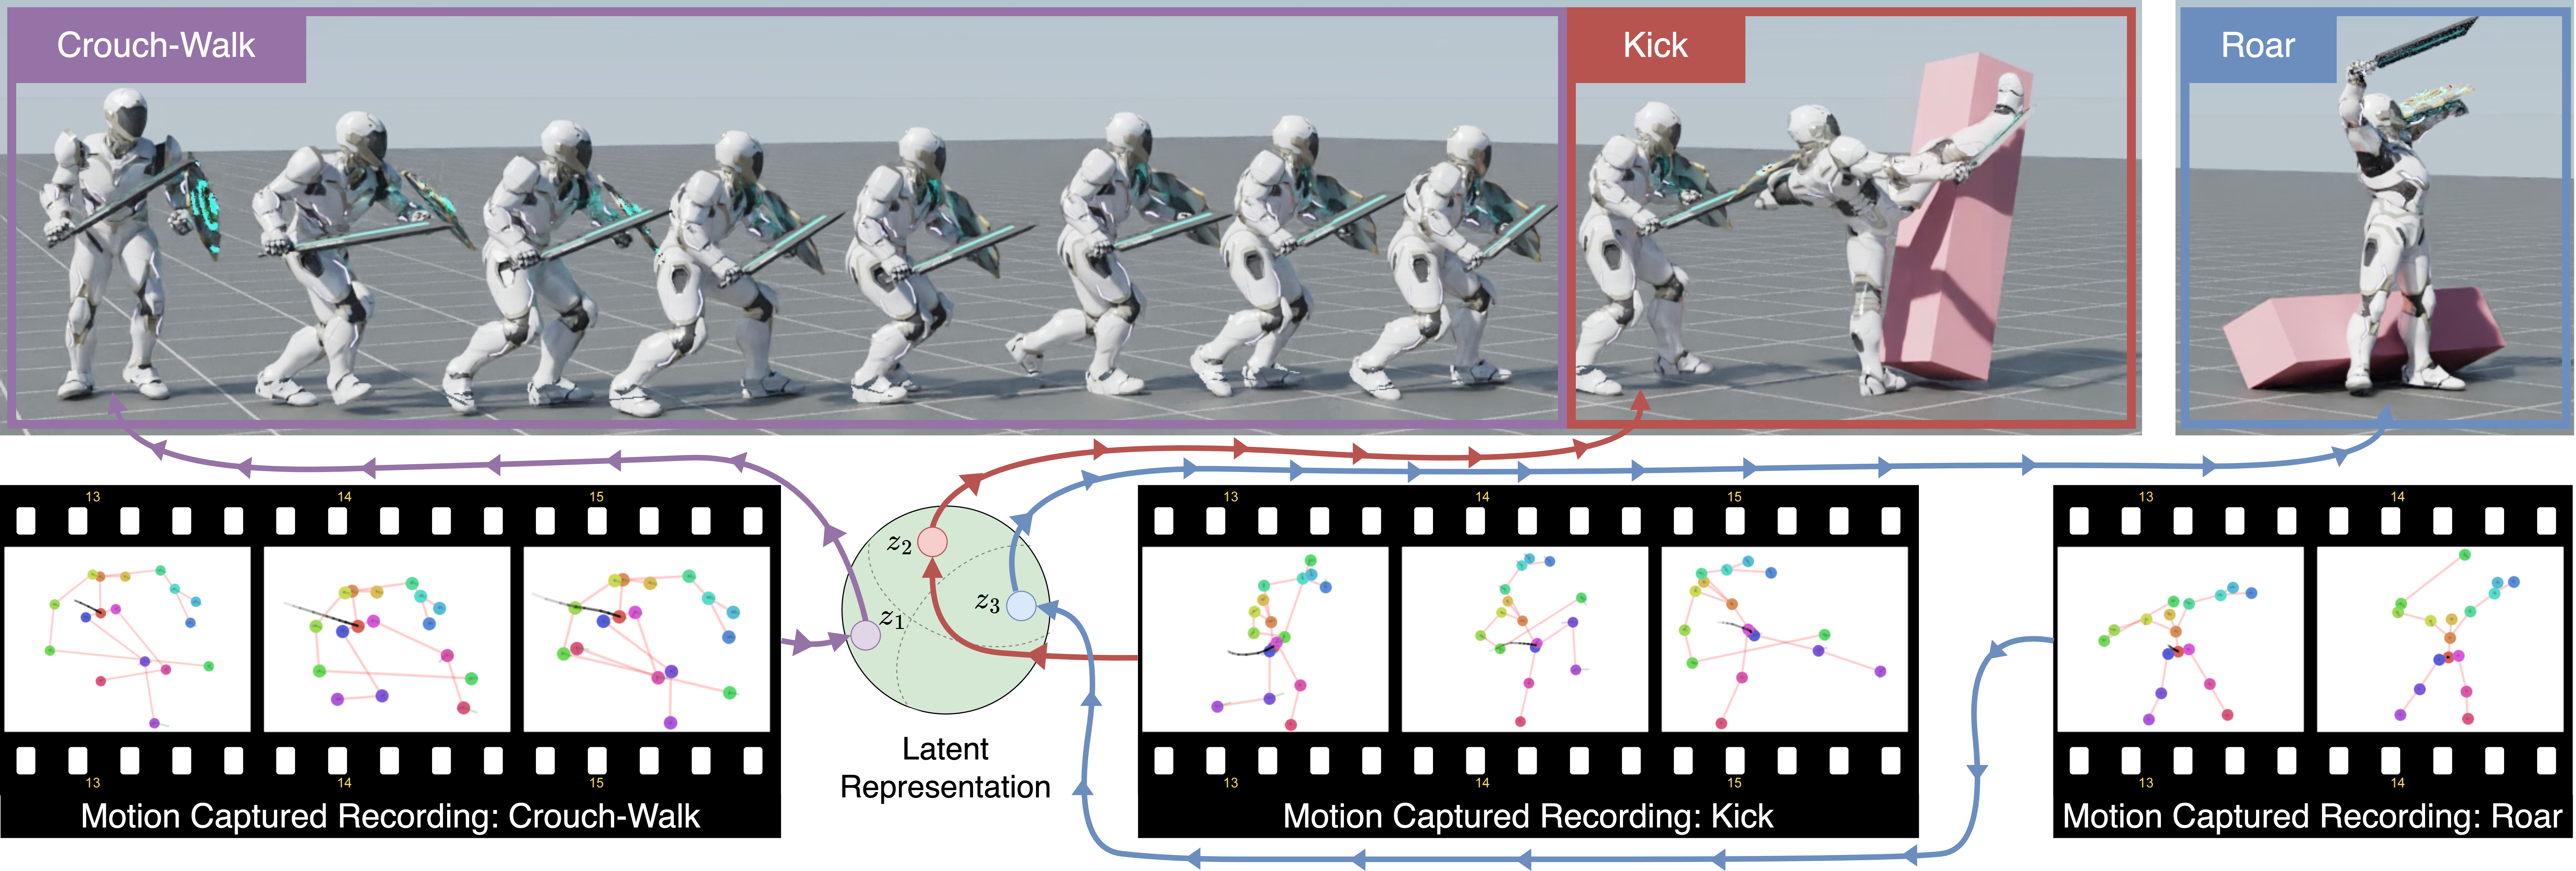
In this work, we present Conditional Adversarial Latent Models (CALM), an approach for generating diverse and directable behaviors for user-controlled interactive virtual characters. Using imitation learning, CALM learns a representation of movement that captures the complexity and diversity of human motion, and enables direct control over character movements. The approach jointly learns a control policy and a motion encoder that reconstructs key characteristics of a given motion without merely replicating it. The results show that CALM learns a semantic motion representation, enabling control over the generated motions and style-conditioning for higher-level task training. Once trained, the character can be controlled using intuitive interfaces, akin to those found in video games.
BibTeX
@inproceedings{
	tessler2023calm,
	author={Tessler, Chen and Kasten, Yoni and Guo, Yunrong and Mannor, Shie and Chechik, Gal and Peng, Xue Bin},
	title = {CALM: Conditional Adversarial Latent Models for Directable Virtual Characters},
	year = {2023},
	isbn = {9798400701597},
	publisher = {Association for Computing Machinery},
	address = {New York, NY, USA},
	url = {https://doi.org/10.1145/3588432.3591541},
	doi = {10.1145/3588432.3591541},
	booktitle = {ACM SIGGRAPH 2023 Conference Proceedings},
	keywords = {reinforcement learning, animated character control, adversarial training, motion capture data},
	location = {Los Angeles, CA, USA},
	series = {SIGGRAPH '23}
}